Why can optical fibers display their bending shape in real-time on a computer like a snake?
A fiber optic system capable of real-time replication of its own spatial bending posture on a computer screen is known as a Fiber Optic Shape Sensor (FOSS) in the fields of optical engineering and sensing.
Its core physical mechanisms and algorithmic implementations are not mysterious; it is essentially a complete chain involving strain measurement based on material mechanics, multi-axis spatial differential decoupling, and three-dimensional differential geometric continuous integration reconstruction:
I. Physical Layer: Bending Strain and Optical Wavelength Drift
When a slender elastic body undergoes bending, according to the Euler-Bernoulli beam deformation theory of material mechanics:
- There exists a neutral axis within the cross-section that experiences neither stretching nor compression;
- The outer side of the bend (convex side) experiences tensile strain (\varepsilon > 0) along the axial direction. The effective grating period of the fiber Bragg grating (FBG) measurement point increases, and the refractive index changes, causing the reflected Bragg wavelength to shift towards longer wavelengths (redshift);
- The inner side of the bend (concave side) experiences compressive strain (\varepsilon < 0) along the axial direction, causing the Bragg wavelength to shift towards shorter wavelengths (blueshift);
- The axial strain \varepsilon at a certain spatial position satisfies a geometric proportional relationship with its perpendicular distance d from the neutral axis and the local bending curvature \kappa:
\varepsilon = -\kappa \cdot d = -\frac{d}{R}
where R is the local radius of curvature.
II. Spatial Perception: Orthogonal Decoupling via Multi-Core/Circumferentially Arranged Multi-Points
A conventional single-mode fiber placed symmetrically along the center can only measure total axial elongation or global temperature, lacking the ability to perceive the directionality of spatial bending. To uniquely determine the bending vector (magnitude of curvature and bending azimuth) in three-dimensional space, a non-collinear multi-channel strain sensing structure must be introduced geometrically:
- Structural Layout: Typically, Multicore Fiber (MCF) (such as multicore fiber Bragg gratings) or arrays of multiple fibers evenly distributed at 120^\circ intervals circumferentially are employed.
- Orthogonal Differential Analysis: In the same axial cross-section of the sensor, three sets of measurement points are located at different azimuthal angles on the outer edge of the cross-section. When the fiber bends in any direction, the three sets of gratings experience different degrees of tensile or compressive wavelength shifts. By solving the differential equations of the relative wavelength shifts among these three sets of measurement points, external environmental temperature fluctuations (common-mode interference) can be eliminated, and the local bending curvature \kappa(s), bending direction angle \theta(s), and possible torsion \tau(s) of the micro-segment can be precisely decoupled.
III. Algorithmic Reconstruction: Differential Geometric Spatial Integration
After obtaining the curvature and direction angle at each cross-section along the fiber’s axis, computer software reconstructs the spatial shape using differential geometric algorithms:
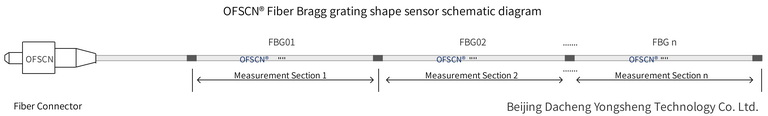
- Spatial Continuous Sampling: Continuous FBG grating measurement points are arranged sequentially along the fiber axis at a certain spatial interval (or using the ultra-high spatial resolution continuous Optical Frequency Domain Reflectometry (OFDR) technique).
- Differential Geometric Integration (Frenet-Serret Frame):
Using a fixed clamp or base at the root of the fiber as the known starting coordinate (x_0, y_0, z_0) and initial tangent orientation basis;
Through a continuous tangent vector transfer matrix algorithm (Transfer Matrix Method) or the Frenet-Serret equations, sequential integration of spatial tangent vectors is performed along the fiber’s arc length s:
\mathbf{r}(s) = \mathbf{r}(0) + \int_0^s \mathbf{T}(u) \, du
- Real-time Graphics Rendering: The fiber demodulator collects the wavelength data of the entire fiber at a fixed sampling frequency. The reconstruction algorithm calculates the 3D spatial coordinates of all points on the fiber’s skeleton within milliseconds to tens of milliseconds. Subsequently, a 3D visualization engine (such as OpenGL/DirectX) refreshes the display in real-time, ultimately presenting a visual effect where the fiber bends and moves synchronously with the physical object, akin to a “live snake.”
IV. OFSCN® Official Related Products and Specifications
Beijing Dacheng Yongsheng Technology Co., Ltd., based on its proprietary fiber Bragg grating packaging and sensor engineering technology, offers related core products and measurement components:
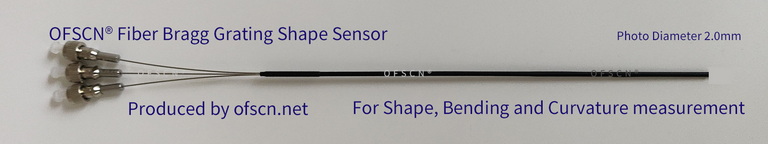
- OFSCN® Fiber Bragg Grating Shape Sensor:
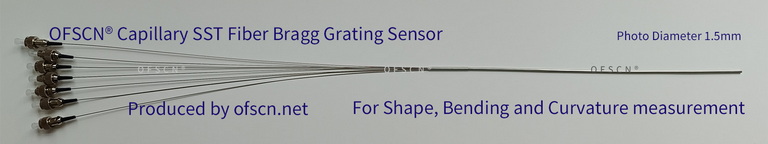
The sensing structure typically employs a substrate material with 3 sets of fiber Bragg grating measurement arrays arranged longitudinally at 120^\circ intervals around the circumference. Standard outer diameters range from 1.5\text{ mm} to 6\text{ mm}. The measurement segment length and spacing between measurement points can be customized according to spatial resolution requirements. - OFSCN® Multicore Fiber Bragg Gratings / FBG Strings (Bare):
Offers multicore fiber Bragg gratings and multicore bare grating strings for shape and bending sensing research and development.