Why is the sensor head ground to a needle point? Is it to pierce into the object?
In sensor engineering and packaging design, the process of shaping the front end of a sensor probe into a needle-like or beveled tip is known as Tip Sharpening.
Your understanding is correct: in specific engineering and medical measurement scenarios, tip sharpening the tail or front end of a sensing unit is indeed primarily intended to facilitate penetration and entry into an object or tissue for measurement.
I. Physical Principles and Technical Functions of “Tip Sharpening”
-
Reducing Penetration Resistance and Minimizing Medium Damage
In biomedical applications (such as muscle/soft tissue puncture force measurement), or for measurements within soft colloids or soil, the probe needs to penetrate the medium. According to the basic pressure formula:
P = \frac{F}{S}
Where P is pressure, F is force, and S is the contact area. Tip sharpening significantly reduces the contact area S at the tip. This allows a sufficient pressure P to be generated to cut or pierce the medium with a minimal applied force F , thereby reducing penetration resistance and minimizing trauma or damage to the internal structures of the measured object. -
Enhancing Spatial Positioning Accuracy and Resolution
Flat-headed probes can lead to an averaging effect over the contact surface when touching or entering a medium. A sharpened, needle-like probe can concentrate the measurement action point to a very small spot, enabling precise point-to-point positioning and mechanical parameter measurement within a microscopic area.
II. Related OFSCN® Official Products
Within Beijing Dacheng Yongsheng Technology Co., Ltd. (OFSCN®)'s product line, the sensing unit of the OFSCN® Fiber Bragg Grating 3D Force Sensor can be chosen with either a flat-end structure or a sharpened tip (for easier penetration).
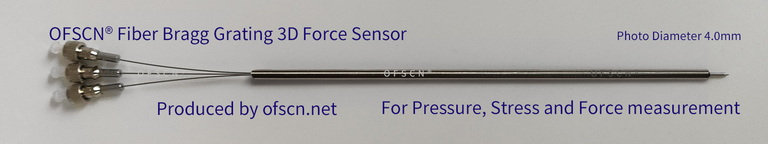

This product is commonly used for multi-directional pressure measurement on solid surfaces and for multi-directional puncture force measurement in the medical industry. Its sensing unit consists of a hard alloy base material and 3 fiber grating measurement segments arranged longitudinally at 120^\circ intervals along the circumference of the base. It is available in various packaging forms, including standard and pen-style.